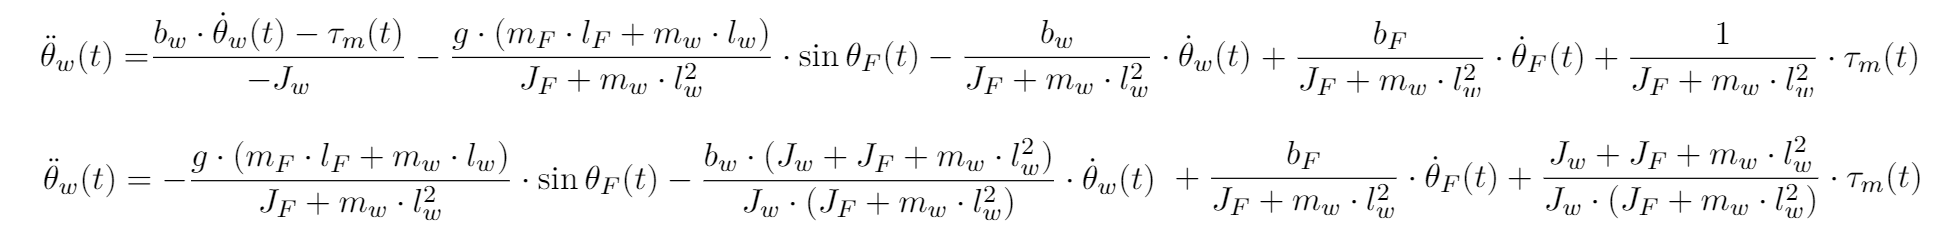
7th semester
LQR Control of the AAU³ Inverted Pendulum
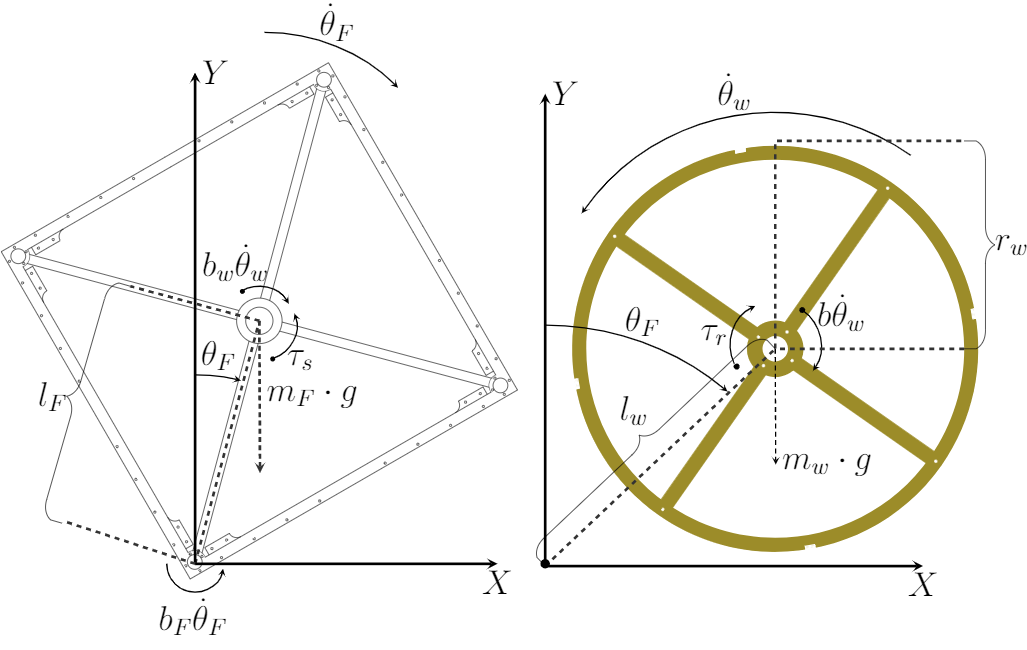
This semester project focused on identifying and modelling the AAU³ inverted pendulum, then investigating control of the system using a Linear Quadratic Regulator.
The original site includes a project poster and supporting figures. These are retained below as downloadable and viewable project material.