Bachelor project
Cubli - Self-balancing Cube
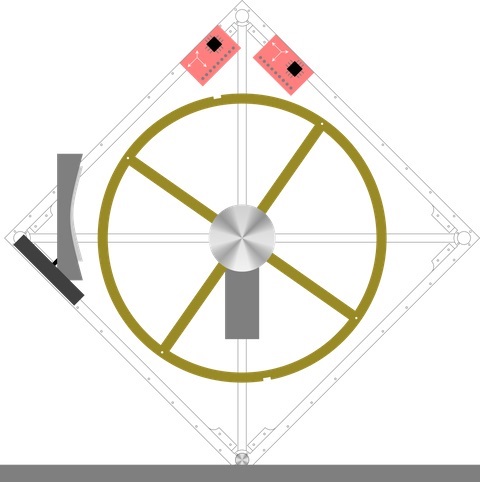
The project investigated an unstable, nonlinear dynamic system using a Cubli from Aalborg University. The cube behaves like an inverted pendulum, with a flywheel used to control its motion and stabilise it.
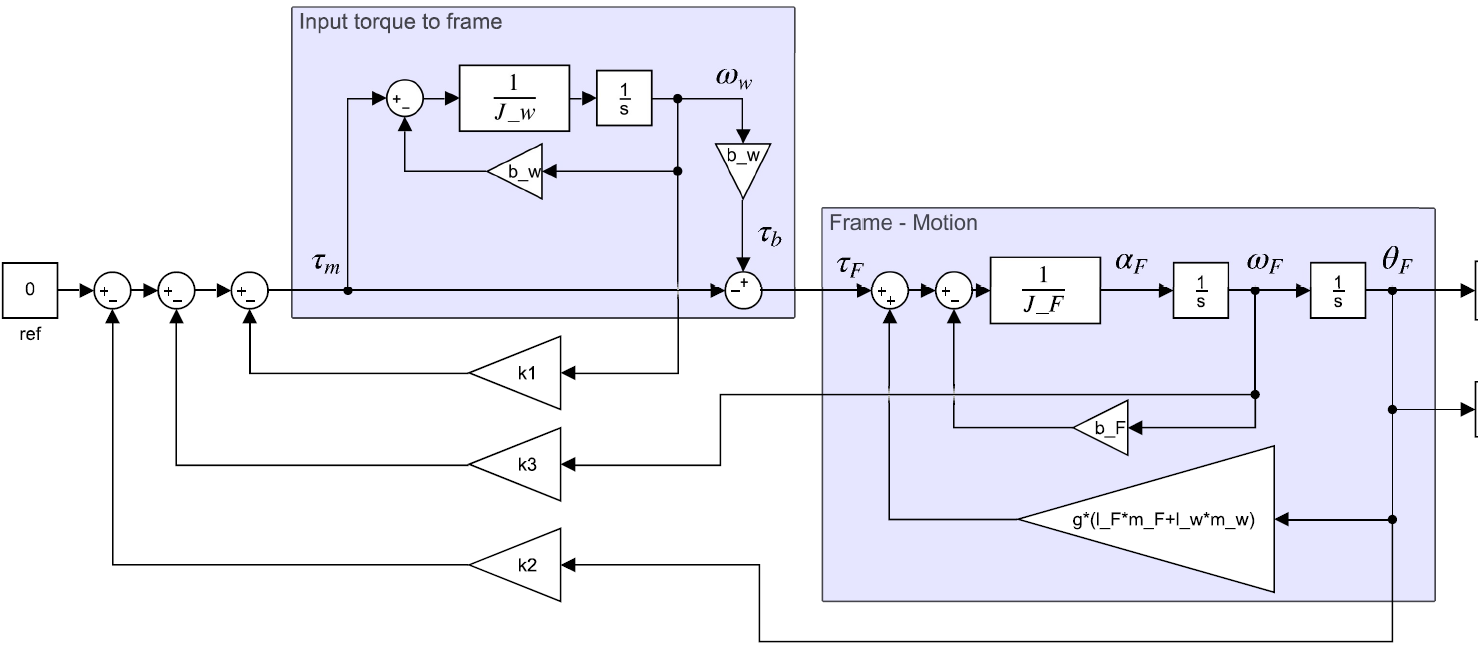
A linear approximation of the system was developed and used to design a controller. After a first design proved too sensitive to uncertainty, pole placement and block-diagram analysis informed a more robust controller. The finished 2D prototype can rise from rest, balance, and counter small external disturbances.