Master project
Sliding Mode Control of a VTOL UAV
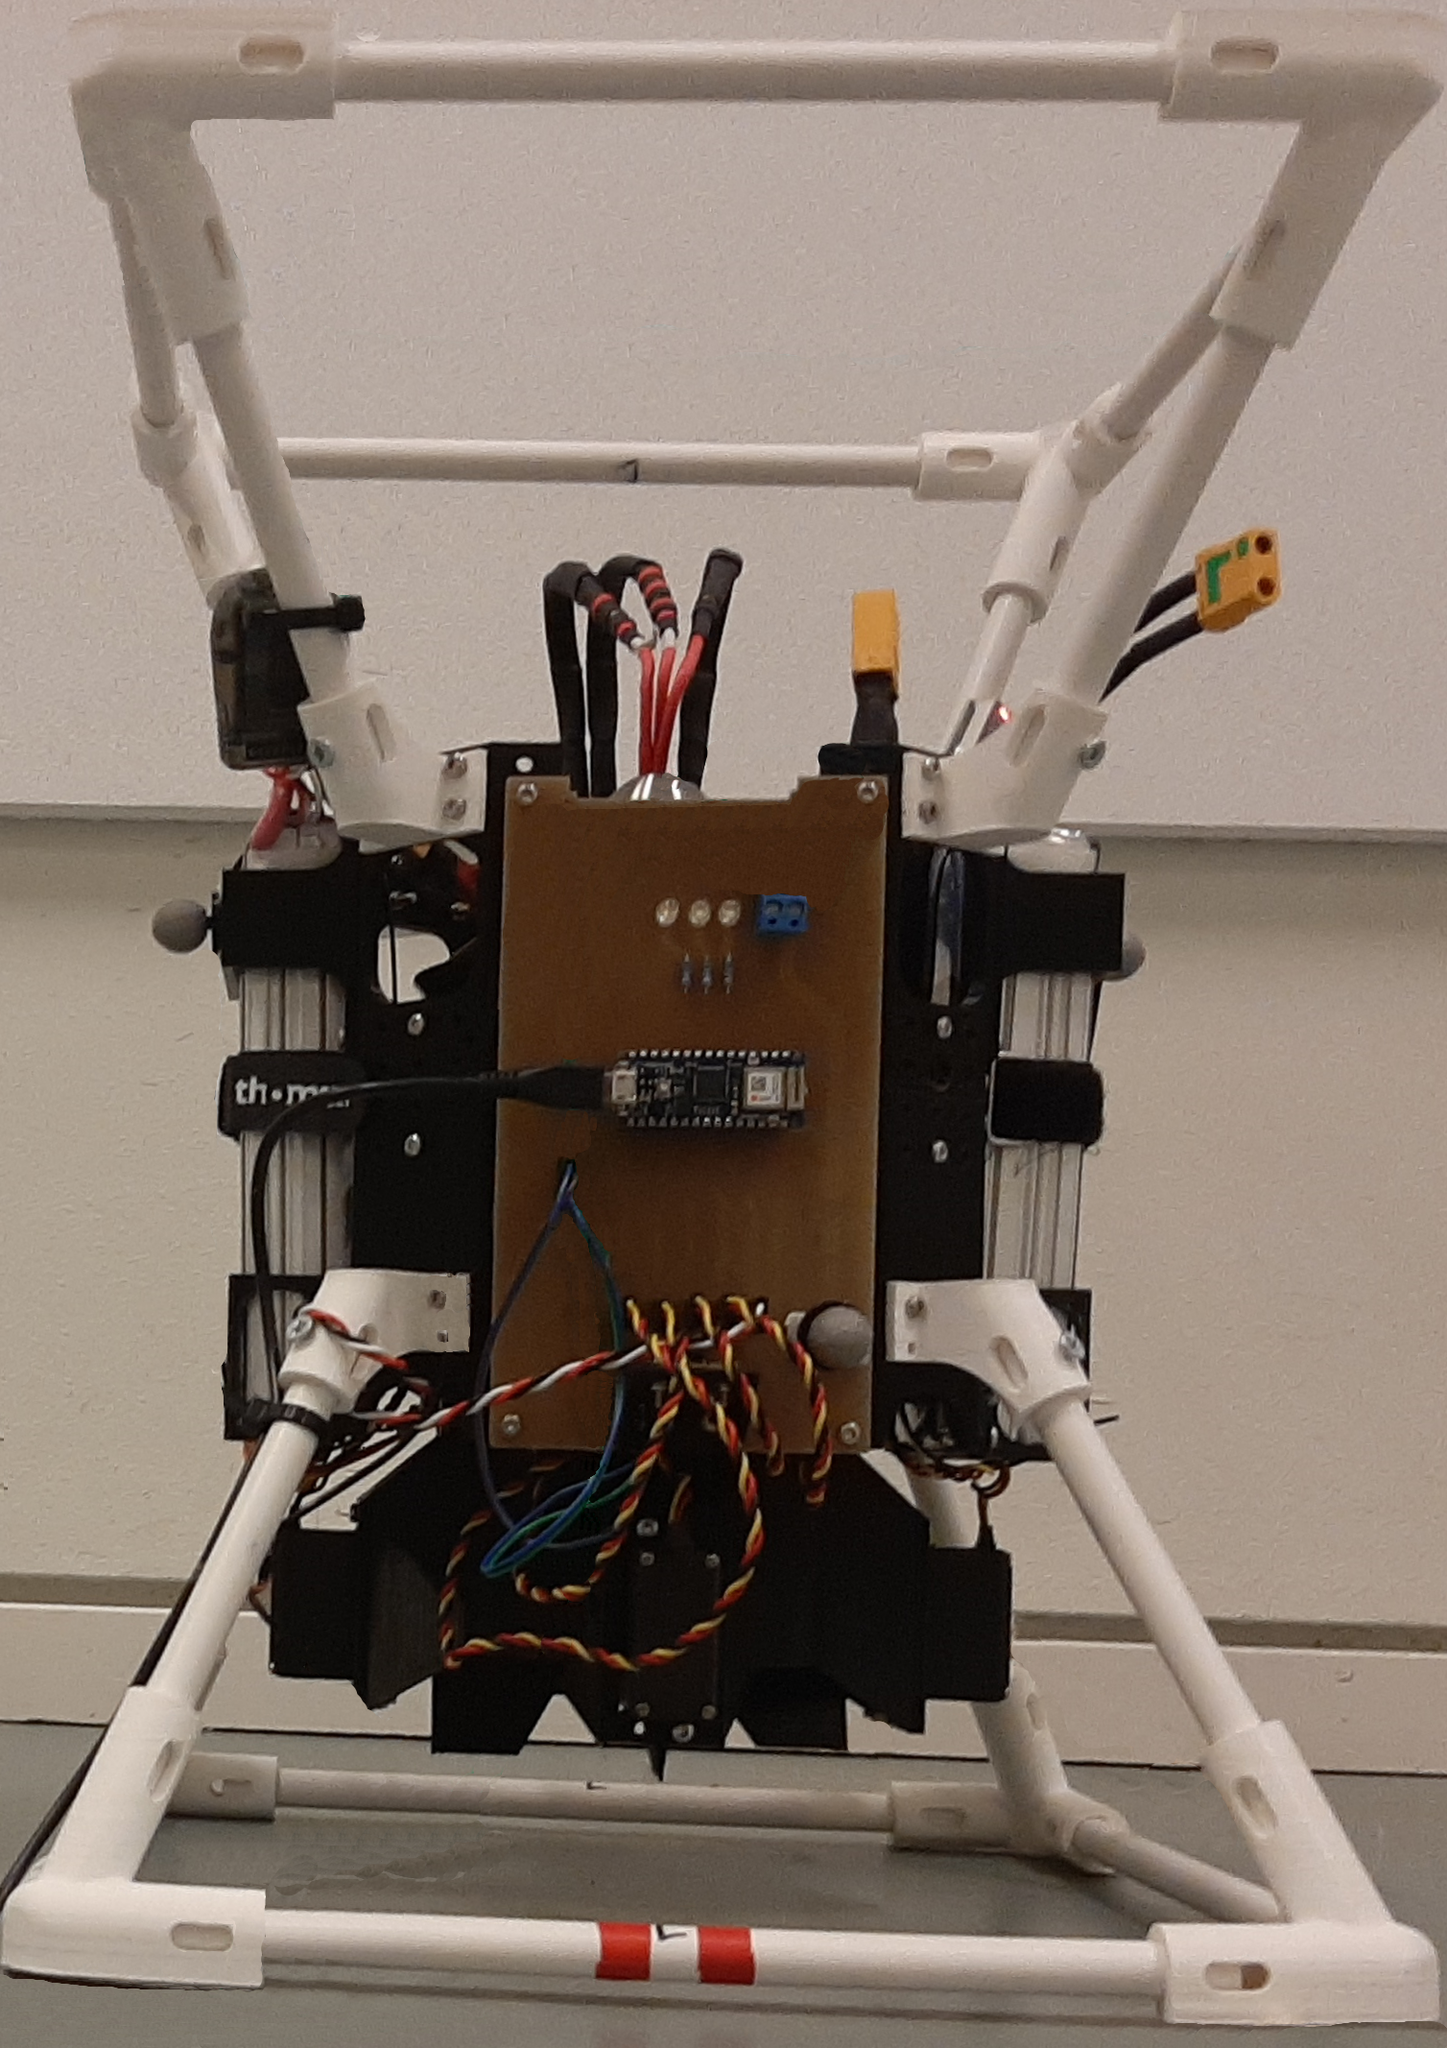
This master project explored how a single-propeller unmanned aerial vehicle can be controlled, in contrast to a conventional quadcopter. The prototype was designed as a test bed for control experiments and future development.
The system was modelled to support nonlinear analysis. A sliding mode controller was implemented, and the finished vehicle demonstrated stable hovering at a set altitude and attitude while sending live data to a ground station.